

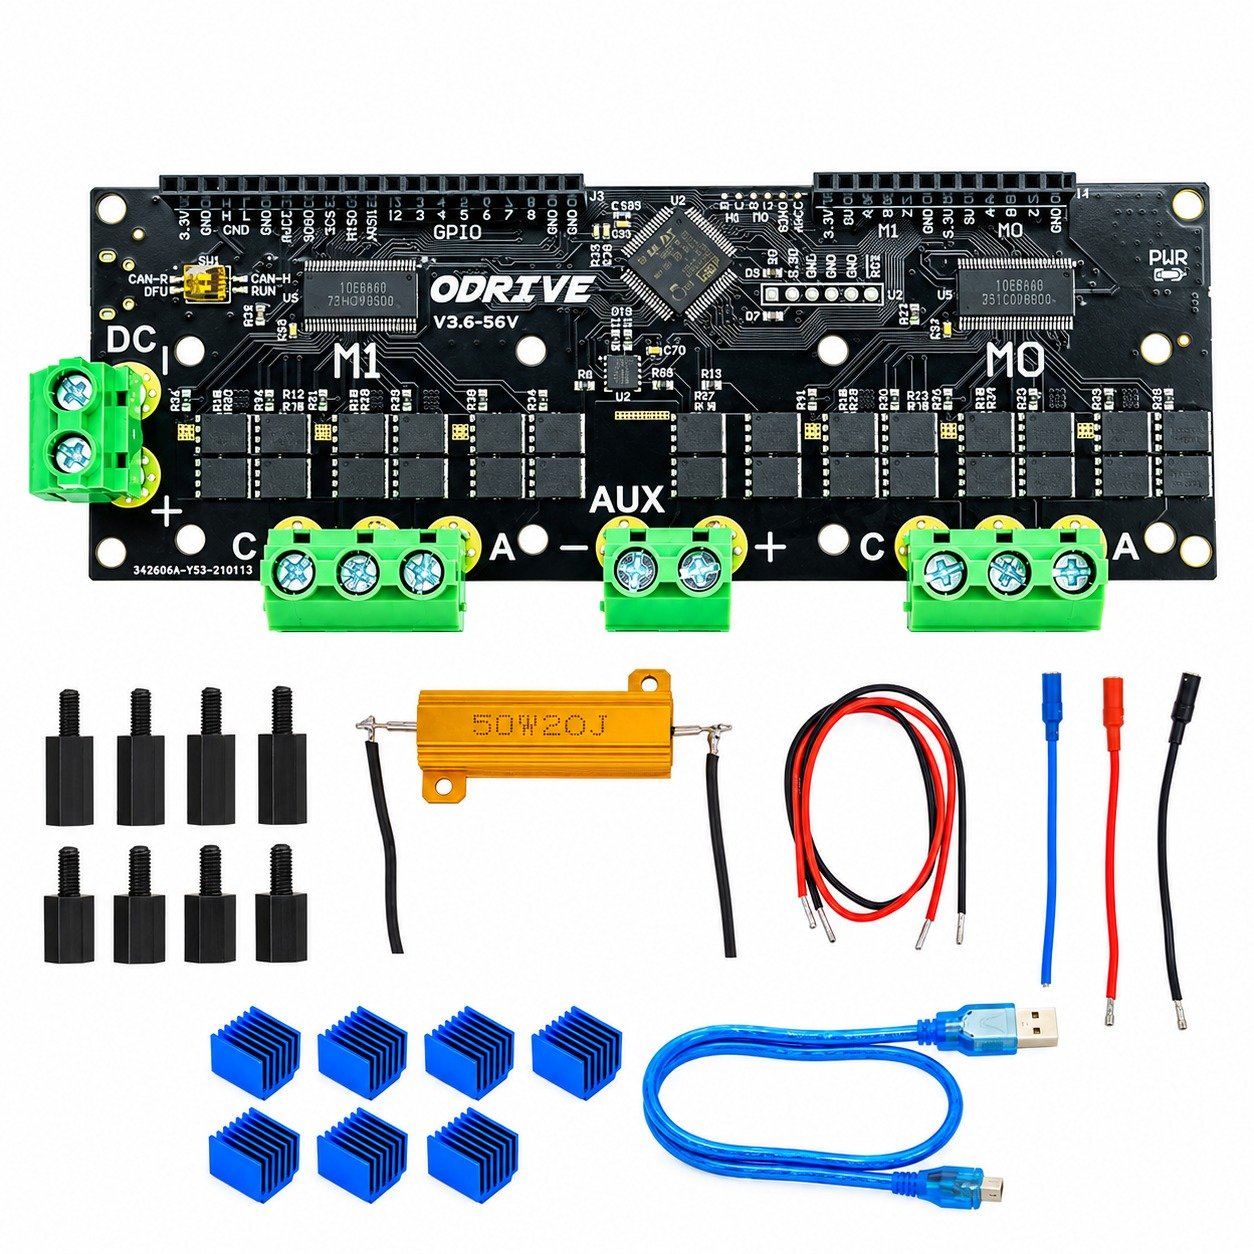
MKS ODrive V3.6 56V High-Power FOC BLDC AGV Servo Dual Motor Controller Board
₹7,383.26 incl. GST (₹6,257.00 + GST)
The ODrive V3.6 Controller Board is a high-performance motor controller designed for precise control of 3-phase BLDC motors. It uses the STM32F405RGT6 MCU and supports 12–48V input, 60A working current, and up to 120A peak current. It provides position, speed, and torque control with USB, UART, PWM, CAN, STEP and DIR interfaces, making it suitable for robotics, CNC, automation, and precision motion applications.
Product Description
The MKS ODrive V3.6 56V High-Power Brushless Motor Controller is a high-performance motion-control board designed for precise control of 3-phase BLDC motors. Based on the ODrive V3.6 hardware platform and powered by the STM32F405RGT6 MCU, it supports advanced position, speed, and torque control for robotics, automation, CNC, gimbal systems, and other precision motion applications.
The controller supports an input voltage range of 12V-48V as specified in the product parameters, with a 60A working current and up to 120A peak current. It provides multiple control and communication interfaces, including USB, UART, PWM, CAN, STEP and DIR, allowing integration with microcontrollers, computers, and motion-control systems.
The controller supports multiple encoder technologies, including TLE5012B, AS5047 and AMT10-series encoders, enabling closed-loop motor control and accurate position feedback. It also supports braking through an external braking resistor or battery recharge, helping manage regenerative energy during motor deceleration.
Features
- ODrive V3.6 based brushless motor controller
- Designed for 3-phase BLDC motors
- Powered by STM32F405RGT6 high-performance MCU
- Supports position, speed and torque control
- 56V Max voltage
- 60A working current
- 120A peak current
- Supports TLE5012B, AS5047, AMT10-series and other compatible encoder types
- Multiple interfaces: USB, UART, PWM, CAN, STEP and DIR
- Supports braking resistor and battery recharge braking modes
- Suitable for high-performance closed-loop motion applications
- Compact controller suitable for robotics and automation
- Includes heatsinks in applicable ODrive package variants
- Micro USB cable included with applicable controller packages
Specifications
Board Parameters
| Parameter | Specification |
|---|---|
| Hardware Version | ODrive V3.6 / 56V Hardware Version |
| MCU | STM32F405RGT6 |
| Input Voltage | 12V-48V |
| Working Current | 60A |
| Peak Current | 120A |
| Motor Type | 3-Phase BLDC Motor |
| Encoder Type | TLE5012B / AS5047 / AMT10-Series and compatible types |
| Interface | USB / UART / PWM / CAN / STEP / DIR |
| Movement Modes | Position / Speed / Torque |
| Braking Mode | Braking Resistor / Battery Recharge |
Included Accessories
| Accessory | Quantity |
|---|---|
| ODrive V3.6 Controller Board | 1 |
| M3×13+6 Mounting Spacers | 4 |
| M3×8+6 Mounting Spacers | 4 |
| Resistor | 1 |
| Power Cable | 1 |
| Heatsinks | 7 |
| Micro USB Cable | 1 |
| Motor Cable (Red, Black, Blue) | 3 |
Working Principle
The MKS ODrive V3.6 works as a closed-loop BLDC motor controller. The STM32F405RGT6 processes the desired motion commands and controls the three-phase motor drive signals.
When an encoder is connected to the motor, the controller receives real-time rotor position information. This feedback allows the controller to regulate motor position, speed and torque accurately.
During deceleration, the motor can generate regenerative energy. The ODrive supports braking through an external resistance or battery recharge, depending on the system configuration.
Encoder Support
The controller is designed to work with various encoder technologies, including:
- TLE5012B
- AS5047
- AMT10-series
- ABI-compatible encoders
- HALL sensors
- SPI encoders
An encoder provides rotor position feedback, which is essential for precise closed-loop motion control.
Communication and Control Interfaces
The MKS ODrive V3.6 provides several interfaces for connecting the controller to external control systems:
- USB – configuration, monitoring and computer-based control
- UART – serial communication
- PWM – PWM-based control
- CAN – CAN bus communication
- STEP/DIR – stepper-style motion command interface
These interfaces make the controller suitable for integration with robotic systems, CNC controllers, embedded systems and automation equipment.
Braking and Regenerative Energy
The ODrive supports regenerative braking during motor deceleration. Depending on the application, generated energy can be handled using:
- External braking resistor(Not included in the package)
- Battery recharge
The supplied braking resistor in applicable packages helps dissipate regenerative energy. Proper mounting and thermal management are required when using the resistor.
Design and Construction
The ODrive V3.6 is designed as a compact high-power motor-control board with dedicated connections for motor, power, encoder and communication interfaces.
Applicable package configurations include heatsinks to assist thermal management during higher-current operation. Proper cooling is important when operating the controller near its higher current limits.
Applications
The MKS ODrive V3.6 is suitable for:
- Robotic arms
- Mobile robots
- CNC machines
- 3D motion systems
- Industrial automation
- Precision positioning systems
- BLDC servo applications
- Gimbal and actuator systems
- Motorized mechanisms
- Research and development
- DIY robotics projects
- Closed-loop motion-control systems
Package Includes
- 1 × ODrive V3.6 Controller Board
-
4 × M3×8+6 Mounting Spacers
-
1 × Resistor
-
1 × Power Cable
-
7 × Heatsinks
-
1 × Micro USB Cable
-
3 × Motor Cables (Red, Black, Blue)
For exact manufacturers specifications and reference docs click here
Product Disclaimer
- The stated 60A working current and 120A peak current depend on operating conditions, motor requirements and adequate thermal management.
- Do not exceed the specified voltage and current limits.
- Proper heatsinking and cooling are recommended for high-current operation. Needs to be purchased seperately
- A suitable encoder may be required for closed-loop position control.
- The braking resistor can become hot during operation and must be installed safely with adequate ventilation.
- Always verify wiring, polarity, motor compatibility and encoder connections before powering the controller.
- Product images and package contents are for reference; actual components may vary slightly depending on the selected variant and production batch.
Frequently Asked Questions
1. What is the MKS ODrive V3.6?
The MKS ODrive V3.6 is a high-performance controller designed for precise control of 3-phase BLDC motors.
2. What type of motor does it support?
It is designed for 3-phase brushless DC (BLDC) motors .
3. What is the input voltage?
The product parameter table specifies an input voltage of 12–48V .
4. What is the working current?
The specified working current is 60A .
5. What is the peak current?
The controller supports a specified 120A peak current , depending on operating and thermal conditions.
6. Which MCU is used?
It uses the STM32F405RGТ6 microcontroller.
7. What control modes are supported?
It supports position, speed and torque control .
8. Does it support encoders?
Yes. It supports compatible encoder technologies such as TLE5012B, AS5047 and AMT10-series encoders .
9. Does the MKS X2212 motor include an encoder?
Yes. The MKS X2212 variant shown includes a TLE5012B encoder installed .
10. What communication interfaces are available?
The controller provides USB, UART, PWM, CAN, STEP and DIR interfaces.
11. Can it be controlled using a computer?
Yes. The USB interface can be used for configuration, monitoring and control with compatible ODrive software/tools.
12. Can it be used with Arduino?
It can be integrated into Arduino-based systems using an appropriate supported communication/control interface such as UART, CAN, PWM or STEP/DIR.
13. Can it be used with Raspberry Pi?
Yes. It can be integrated with Raspberry Pi-based robotics and automation systems through compatible interfaces.
14. Does it support CAN communication?
Yes, CAN is one of the supported communication interfaces.
15. What is regenerative braking?
During motor deceleration, the motor can generate electrical energy. The controller can manage this energy using a braking resistor or battery recharge configuration .
Only logged in customers who have purchased this product may leave a review.



Reviews
There are no reviews yet